Data-Efficient Robot Learning
in Deployment
1 Department of Electrical Engineering and Computer Sciences, University of California, Berkeley, United States
Mulligan steers supervised collection toward the initial states where a robot fails. We combine targeted corrections and demonstrations with a value function that learns from every rollout, including failures.
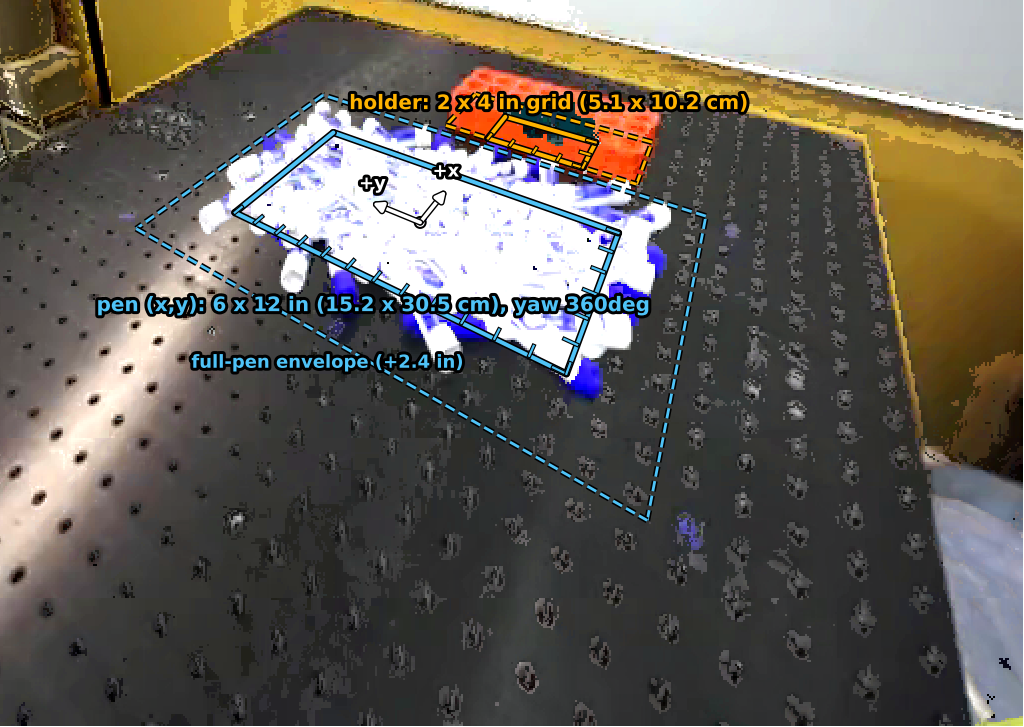
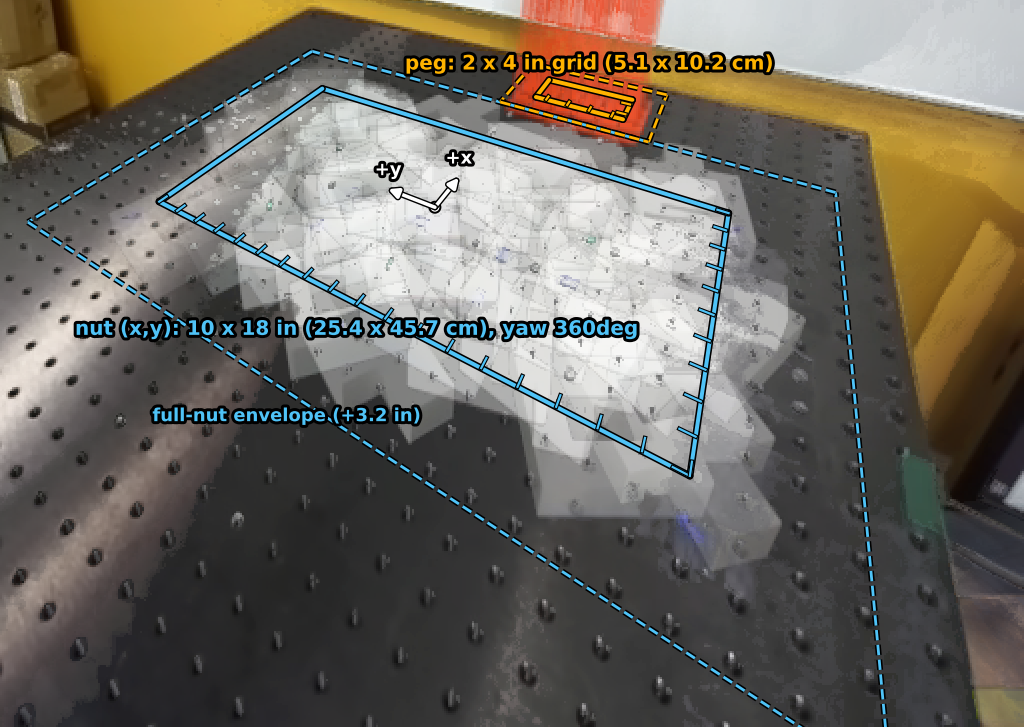
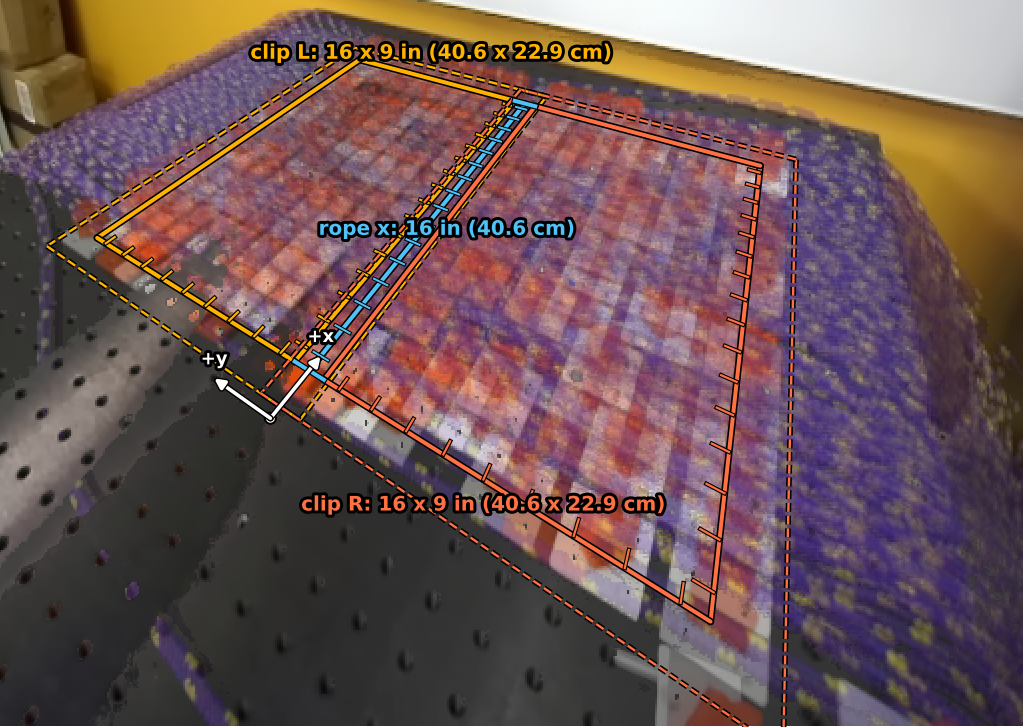
Across three real tasks, the full method improves final success by 14–34 percentage points over HG-DAgger at matched supervised collection budgets.